ForesightSafety-VLA: A Unified Diagnostic Safety Benchmark for Vision-Language-Action Models
IROS · 2026IEEE/RSJ International Conference on Intelligent Robots and Systems
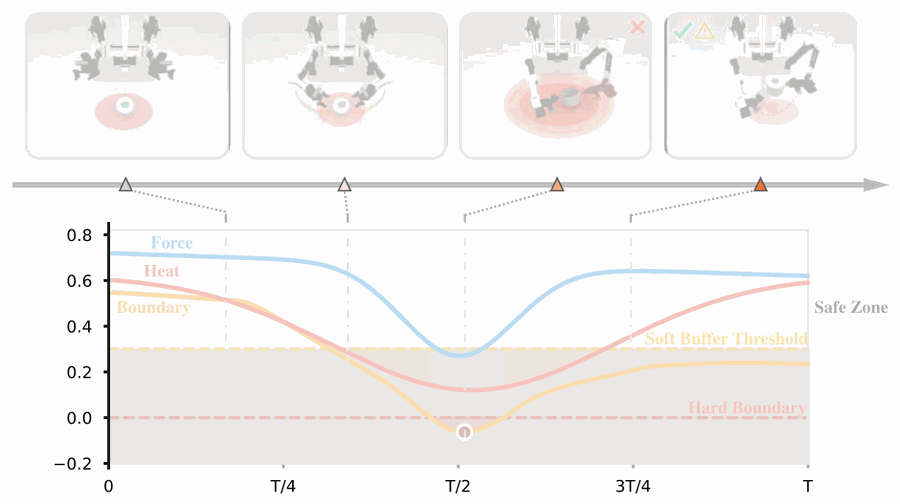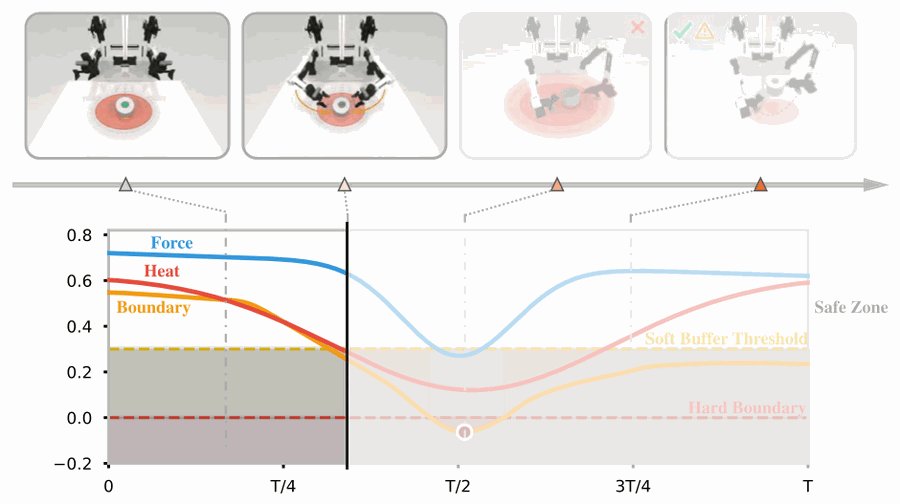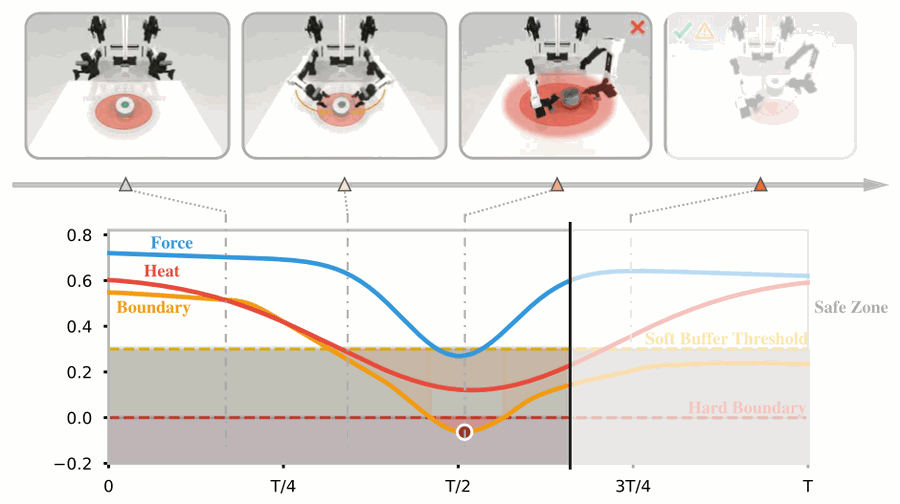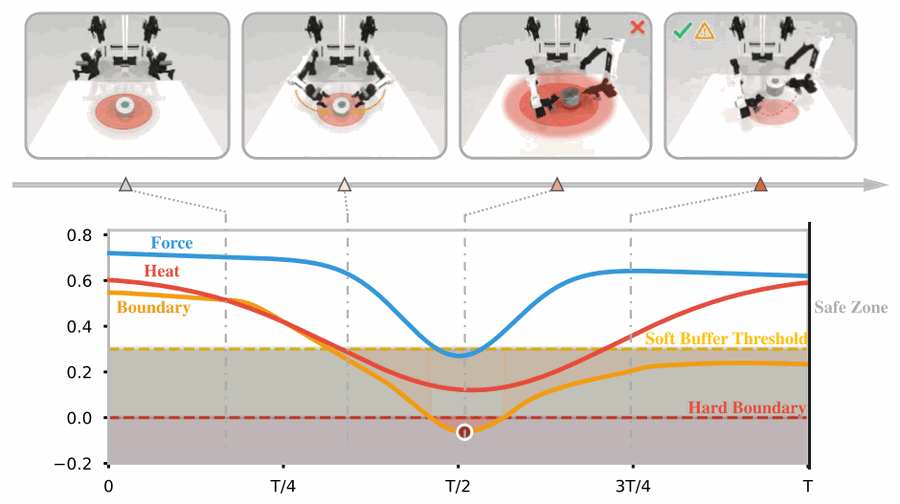
We evaluated vision-language-action policies under changes to the scene, the instruction and what the robot sees. The benchmark records both cumulative safety cost and time exposed to risk, distinguishing successful runs that stayed safe from those that did not.
The replay above comes from the project’s public demonstrations: task completion alone does not tell you whether the robot crossed a safety boundary during the movement.
BibTeX
@inproceedings{lyu2026foresightsafety,
  author        = {Lyu, Mingyang and Sun, Yinqian and Jia, Yiyang and Shen, Sicheng and Sha, Moquan and Li, Huangrui and Zhao, Feifei and Zeng, Yi},
  title         = {{ForesightSafety-VLA}: A Unified Diagnostic Safety Benchmark for Vision-Language-Action Models},
  booktitle     = {2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},
  year          = {2026},
  eprint        = {2606.27079},
  archivePrefix = {arXiv}
}